Base class for explicit time integration schemes. More...
#include "ExplicitModule.h"
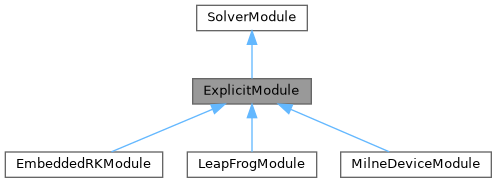
Inheritance diagram for ExplicitModule:
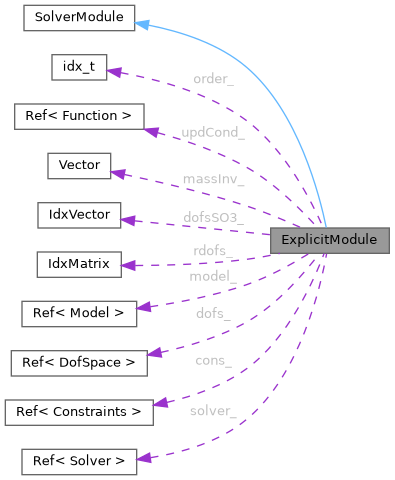
Collaboration diagram for ExplicitModule:
Public Types | |
| enum | MassMode { LUMPED , CONSISTENT } |
| Mass matrix formulation modes. More... | |
Public Member Functions | |
| virtual Status | init (const Properties &conf, const Properties &props, const Properties &globdat) override |
| Initialize the module. | |
| virtual void | shutdown (const Properties &globdat) override |
| Shutdown the module. | |
| virtual void | configure (const Properties &props, const Properties &globdat) override |
| Configure the module from properties. | |
| virtual void | getConfig (const Properties &props, const Properties &globdat) const override |
| Get current module configuration. | |
| virtual void | advance (const Properties &globdat) override |
| Advance to next time step. | |
| virtual void | solve (const Properties &info, const Properties &globdat) override=0 |
| Solve current time step (pure virtual) | |
| virtual void | cancel (const Properties &globdat) override |
| Cancel current solution attempt. | |
| virtual bool | commit (const Properties &globdat) override |
| Compute next step size and commit solution. | |
| virtual void | setPrecision (double eps) override |
| Set convergence precision. | |
| virtual double | getPrecision () const override |
| Get current convergence precision. | |
Static Public Attributes | |
Property identifiers | |
| static const char * | TYPE_NAME = "Explicit" |
| Module type name. | |
| static const char * | STEP_COUNT = "stepCount" |
| Step count property. | |
| static const char * | SO3_DOFS = "dofs_SO3" |
| SO(3) DOF types property. | |
| static const char * | LEN_SCALE = "lengthScale" |
| Length scale property. | |
Protected Member Functions | |
| ExplicitModule (const String &name="") | |
| Protected constructor. | |
| virtual | ~ExplicitModule () |
| Protected destructor. | |
| void | updateMass_ (const Properties &globdat) |
| Update mass matrix. | |
| void | invalidate_ () |
| invalidate_ current state | |
| void | ABupdate (const Vector &delta_y, const Vector &f_cur, const Vector &f_old) const |
| Adams-Bashforth 2-step update. | |
| void | ABupdate (const Vector &delta_y, const Vector &f_cur) const |
| Adams-Bashforth 1-step update (explicit Euler) | |
| void | updateVec (const Vector &y_new, const Vector &y_old, const Vector &delta_y, const bool rot=false) |
| Update displacement vectors with optional SO(3) handling. | |
| void | getAcce (const Vector &a, const Ref< Constraints > &cons, const Vector &fres, const Properties &globdat) |
| Get acceleration and return resulting force vector. | |
| Vector | getForce (const Vector &fint, const Vector &fext, const Properties &globdat) |
| Get force vector. | |
| double | getQuality (const Vector &y_pre, const Vector &y_cor) |
| Get solution quality measure. | |
Protected Attributes | |
Module state | |
| bool | valid_ |
| State validity flag. | |
Time stepping parameters | |
| double | dtime_ |
| Current time step size. | |
| double | prec_ |
| Precision tolerance. | |
| double | minDtime_ |
| Minimum time step size. | |
| double | maxDtime_ |
| Maximum time step size. | |
| double | saftey_ |
| Safety factor for step size control. | |
| double | incrFact_ |
| Step size increase factor. | |
| double | decrFact_ |
| Step size decrease factor. | |
Integration parameters | |
| MassMode | mode_ |
| Mass matrix mode. | |
| idx_t | order_ |
| Integration order. | |
| double | lenScale_ |
| Characteristic length scale. | |
DOF management | |
| Ref< Function > | updCond_ |
| Update condition function. | |
| Vector | massInv_ |
| Inverse mass matrix. | |
| IdxVector | dofsSO3_ |
| SO(3) DOF type indices. | |
| IdxMatrix | rdofs_ |
| Rotational DOF mapping. | |
System components | |
| Ref< Model > | model_ |
| Root of the model tree. | |
| Ref< DofSpace > | dofs_ |
| Degree of freedom space. | |
| Ref< Constraints > | cons_ |
| Constraint manager. | |
| Ref< Solver > | solver_ |
| Linear solver. | |
Detailed Description
Provides foundation for explicit solvers with support for rotational DOFs, adaptive time stepping, and both lumped and consistent mass matrices. Handles special integration of SO(3) rotational degrees of freedom using exponential maps.
Member Enumeration Documentation
◆ MassMode
Constructor & Destructor Documentation
◆ ExplicitModule()
|
explicitprotected |
- Parameters
-
name Module name
◆ ~ExplicitModule()
|
protectedvirtual |
Member Function Documentation
◆ ABupdate() [1/2]
|
inlineprotected |
- Parameters
-
delta_y Displacement increment f_cur Current force vector
◆ ABupdate() [2/2]
|
inlineprotected |
- Parameters
-
delta_y Displacement increment f_cur Current force vector f_old Previous force vector
◆ advance()
|
overridevirtual |
- Parameters
-
globdat Global data container
◆ cancel()
|
overridevirtual |
- Parameters
-
globdat Global data container
◆ commit()
|
overridevirtual |
- Parameters
-
globdat Global data container
- Returns
- true if step can be accepted
◆ configure()
|
overridevirtual |
- Parameters
-
props User-specified module properties globdat Global data container
◆ getAcce()
|
protected |
- Parameters
-
a Acceleration vector (output) cons Constraint manager fres Resulting force vector globdat Global data container
◆ getConfig()
|
overridevirtual |
- Parameters
-
props Actually used configuration properties (output) globdat Global data container
◆ getForce()
|
protected |
- Parameters
-
fint Internal force vector fext External force vector globdat Global data container
- Returns
- Resulting force vector (external - internal)
◆ getPrecision()
|
overridevirtual |
- Returns
- Current convergence tolerance
◆ getQuality()
|
protected |
- Parameters
-
y_pre Predicted solution y_cor Corrected solution
- Returns
- Quality measure
◆ init()
|
overridevirtual |
- Parameters
-
conf Actually used configuration properties (output) props User-specified module properties globdat Global data container
- Returns
- Module status
Reimplemented in EmbeddedRKModule.
◆ invalidate_()
|
protected |
◆ setPrecision()
|
overridevirtual |
- Parameters
-
eps Convergence tolerance
◆ shutdown()
|
overridevirtual |
- Parameters
-
globdat Global data container
◆ solve()
|
overridepure virtual |
- Parameters
-
info Solver information globdat Global data container
Implemented in EmbeddedRKModule, LeapFrogModule, and MilneDeviceModule.
◆ updateMass_()
|
protected |
- Parameters
-
globdat Global data container
◆ updateVec()
|
protected |
- Parameters
-
y_new New displacement vector y_old Old displacement vector delta_y Displacement increment rot Flag for rotational DOFs
Member Data Documentation
◆ cons_
|
protected |
◆ decrFact_
|
protected |
◆ dofs_
|
protected |
◆ dofsSO3_
|
protected |
◆ dtime_
|
protected |
◆ incrFact_
|
protected |
◆ LEN_SCALE
|
static |
◆ lenScale_
|
protected |
◆ massInv_
|
protected |
◆ maxDtime_
|
protected |
◆ minDtime_
|
protected |
◆ mode_
|
protected |
◆ model_
|
protected |
◆ order_
|
protected |
◆ prec_
|
protected |
◆ rdofs_
|
protected |
◆ saftey_
|
protected |
◆ SO3_DOFS
|
static |
◆ solver_
|
protected |
◆ STEP_COUNT
|
static |
◆ TYPE_NAME
|
static |
◆ updCond_
|
protected |
◆ valid_
|
protected |